2019/11/21 (Thursday)
| Setup | DIB1/2/4 → 3.2 MHz filters → cable 1/2/3 → gender changer 1/2/3 → movable source controller/board with external Feedback resistor/nothing → DCRC55(1)/DCRC33(2)/DCRC50(3) |
|---|---|
| Overnight | Ran a script that moved the source a few steps every few min. Tower ranged between 75-400 mK. The program was set to run 120 moves. The last move was at 1:16:39 AM according to the temperature. The first “good” move was at 5:19:15 pm yesterday. It looks like 4.01 minutes per move, so that's 120 “good” moves. But there's also one additional temperature excursion before that (5:15:33 pm), where the temperature didn't rise sharply and didn't rise nearly as much, 160 mK max. |
| 0700 | Tower = 32.6 mK. That seems to be the base now, after several hours left alone. |
| 0738 | Do a hot Al flash for 90s using the sequence Al_flash.msl. Tower peaks at 1.6 K. |
| 0855 | Final motor waveform on the scope looks okay, Vtrim flat at +/- 0.5V. |
| 0856 | Tower/MC/Coldplate = 33.9/30.2/192 mK, Still = 1.50 K/ 0.130 mbar / 0 mW, G1/G2= 236/224 mbar, 1K Pot = 1.63 K / 20±1 mbar. MB = 32.9% |
| 0900 | Fill LN2 cold trap bath. |
| 0902 | Turn off motor power supply, power down arduino, and disconnect Keithley meter. |
| 0910 | Start 1x S1/S2=-4/+4,+4/-4 V loop of 30 min Bkg data series, Driver gain = 1, with 1000 initial randoms, with 30s flashes and 30 min cooldowns trigger on DCRC2pA/B/C = 8/8/8 ADC using sequence qbias_mp4_pm4_loop.msl |
| 1125 | Sure looks like the last two datasets are still at the endstop. We may be stuck there either because something jammed or for some reason the motor won't step in the opposite direction. Let's just end this run by taking some more phonon collection efficiency data by doing more Al flashes. |
| 1128 | Do 90 s hot Al flash. |
|---|---|
| 1150 | On second thought, let's first try to get the source unstuck by bumping up the motor current. Power arduino and connect to it via telnet. Set motor power supply to 8.0 V and turn on scope. Set dwell to 40 ms. Adjust motor current rotary pot on motor driver board. It was at minimum setting, turn it up about 1/4 turn. |
| 1157 | Tower = 50.6 mK. Move -4 steps. Tower spikes to 400 mK, step current is flat at +/- 0.75 V, endstop2 resistance = 19 Ω. |
| 1200 | Change back to monitoring motor coil A voltages. |
| 1202 | Tower = 61.8 mK. Move -6 steps. Tower spikes to 540 mK, messed up the scope probe,s o not sure what the V_trim signal did, endstop2 resistance = 19 Ω. |
| 1208 | Tower = 73.1 mK. Move -6 steps. Tower spikes to 550 mK, step current is flat at +/- 3.5 V until maybe the final step where it starts to fall, endstop2 resistance = 19 Ω. |
| 1213 | Turn motor rotary pot up to about 1/2 of maximum. |
| 1214 | Tower = 72.2 mK. Move -6 steps. Tower spikes to mK, step current is flat at +/- 3.5 V until maybe the final step where it starts to fall, endstop2 resistance = 19 Ω. |
| 1216 | Turn motor rotary pot up to maximum. |
| 1219 | Tower = 81.8 mK. Move -6 steps. Tower spikes to 875 mK, step current goes to +/- 4.0 V, drive current is probably railing at +/-6.5 V,drive current is clearly falling by 3rd step, endstop2 resistance = 19 Ω. |
| 1222 | Turn motor rotary pot down to 3/4 maximum. |
| 1229 | Tower = 78 mK. Move -6 steps. Tower spikes to 725 mK, step current goes to +/- 3.5 V, drive current is probably railing by the final steps, but looks like ~4 decent steps are occurring, endstop2 resistance = 68 Ω. |
| 1237 | Tower = 87 mK. Move -4 steps. Tower spikes to 475 mK, step current goes to +/- 3.5 V, looks like ~4 decent steps are occurring, endstop2 resistance = 35 Ω. |
| 1240 | Quit arduino telnet session. |
| 1242 | Tower = 102 mK. Move 10x-4 steps with 4 min wait in between using stepper_loop.py. |
| 1243 | endstop2 resistance = 208 Ω after first move, but I'm not getting my hopes up yet. |
| 1246 | endstop2 resistance = 192 Ω after 2nd move, but it briefly spiked to ~1 kΩ like it's trying to break free! C'mon lil motor, you can do it! |
| 1250 | endstop2 resistance = 75 Ω after 3rd move, but again briefly spiked to ~1 kΩ. |
| 1316 | For 2 of the periods between moves, endstop2 resistance stayed ~1 kΩ and the tower only cooled to 225 mK instead of ~125 mK like the other steps. |
| 1318 | endstop2 resistance = 2.5 kΩ at the end of the sequence. |
| 1320 | Turn motor rotary pot up to 7/8 maximum. |
| 1324 | Tower = 270 mK. Ohh, the temperature was staying high due to the Keithley measuring the resistance. Disconnecting these leads let's the temp fall back down. |
| 1326 | Tower = 124 mK. Move 10x-4 steps with 4 min wait in between using stepper_loop.py. Tower spikes to 750 mK. |
| 1330 | endstop2 resistance = 16 kΩ after 2nd step. |
| 1338 | endstop2 resistance = 8.8 GΩ after 3rd step, we're (probably) free! |
| 1340 | endstop2 resistance = 3.4 GΩ and falling after 4th step… |
| 1345 | endstop2 resistance = 54 Ω after 5th step… |
| 1351 | Start LHe transfer @ MB = 25.4% |
| 1412 | endstop2 resistance = 5 GΩ and rising at the end of the sequence. Reduce motor driver current pot to 3/4 of maximum. |
| 1414 | Tower = 76 mK. Move 10x-4 steps with 4 min wait in between using stepper_loop.py. Motor drive current looks icky, current falls by 2nd step on first move. Tower spikes to 750 mK. |
| 1419 | 2nd move looks similarly crummy, reduce motor driver current pot to 1/2 of maximum. endstop2 resistance = 35 GΩ |
| 1420 | End LHe transfer @ MB = 92.8% |
| 1440 | endstop2 resistance = 32 GΩ after 7th move. Didn't check moves 3 through 6 |
| 1444 | endstop2 resistance = 43 GΩ after 8th move. |
| 1448 | endstop2 resistance = 24 GΩ after 9th move. |
| 1501 | endstop2 resistance = 6 GΩ and rising after 10th move. This is taken at low temperature and it drifted upward - I think the measurement is temperature dependent, and has to settle. At any rate we've been getting >GΩ repeatedly. Looks kinda like we are free of the endstop. |
| 1520 | Reduce motor driver current pot back to minimum. This is how we'd been operating before getting stuck. |
| 1523 | Tower = 42 mK. Move 231x-4 steps with 4 min wait in between using stepper_loop.py. Pipe this output to /home/mast/cdms/arduino/stepper_loop.out. We estimate this will take us back to center and take 15.4 hours. |
| 1528 | endstop2 resistance = 121 GΩ |
| 1530 | Motor waveforms don't look great, Vtrim current falling by 2nd step. Try and turn the motor driver current adjust pot up and back down again in case there's some hysteresis there. |
| 1532 | Motor waveforms still don't look great. Disconnect Keithley probes. |
| 1537 | Motor waveforms still don't look great, 4th move. |
| 1546 | Kill the stepping sequence after the 6th move. Turn arduino and motor power supply off and back on. Set dwell to 40 ms, quit arduno telnet session. |
| 1549 | Tower = 100 mK. Move 225x-4 steps with 4 min wait in between using stepper_loop.py. Pipe this output to /home/mast/cdms/arduino/stepper_loop.out. We estimate this will take us back to center and take 15.4 hours. |
| 1551 | Motor waveforms still don't look great… |
| 1558 | After the 3rd move attempt, reduce power supply voltage to 7.5 V in an attempt to limit the drive current and heating. |
| 1602 | This reduced 4th move tower spike from 700 mK to 650 mK, but the motor drive current still looks like it's falling off by the 2nd step. Reduce further to 7.0 V. |
| 1626 | Tower spikes reduced from 650 mK to 620 mK, but the motor drive current waveform still looks bad. After 10th move, reduce further to 6.5 V. |
| 1631 | This looks much better. Tower spike fell from 620 to 420 mK, and the waveforms look very nice now. |
| 1635 | Bleah - 11th move was nice, but 12th move looks junkier, and heated more: to 520 mK. Gonna adjust to 6.4 V |
| 1638 | 13th is sorta like 12th. Not bad - Nick thinks it looks like maybe 3 steps. Probably at least 2. |
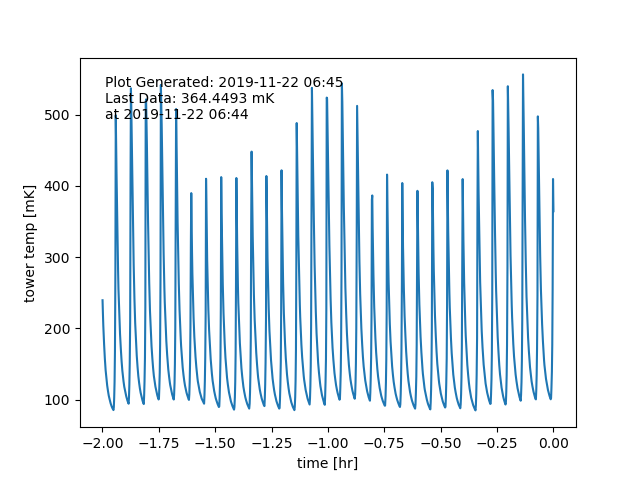 |
| temperature pattern suggests some good moves (lower temp spikes), some bad. |