2019/11/18 (Monday)
| Setup | DIB1/2/4 → 3.2 MHz filters → cable 1/2/3 → gender changer 1/2/3 → movable source controller/board with external Feedback resistor/nothing → DCRC55(1)/DCRC33(2)/DCRC50(3) |
|---|---|
| 0925 | Tower/MC/Coldplate = 33.8/30.3/194 mK, Still = 1.55 K/ 0.130 mbar / 0 mW, G1/G2= 236/225 mbar, 1K Pot = 1.64 K / 25±1 mbar. MB= 65.3% |
| 1045 | Fill LN2 cold trap full. |
| 1050 | Given the tests last week, we have probably only been moving a few (2-4?) steps before coil heating limits the current each time we try to move. We're tried to move 14 times, so estimate the most we might have actually moved is ~14*4 steps*16.54 μm/step = 0.93 mm. Our only hope in this current run to see movement is to try a bunch of these little steps and search for a hint of movement in phonon signals. |
| 1216 | Modified the arduino code to shorten the time between wake-up and first steps when in autosleep mode from 100 ms to 5 ms. The A3967 stepper chip on the driver board really only needs ~1 ms for this time. |
| 1220 | Power and connect to arduino. Power motor power supply to 8.0 V. Set dwell to 8 ms. |
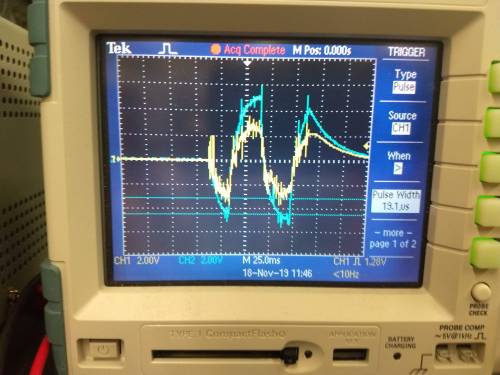
| 1223 | Move by +6 steps with command mv +6. Tower spikes to 405 mK. Coil voltage waveforms show that we're not reaching flat square waves, forgot we have the smoothing capacitors so the steps have ~20 ms rise time. |
| 1232 | Tower = 57.9 mK |
|---|---|
| 1233 | Set dwell to 40 ms |
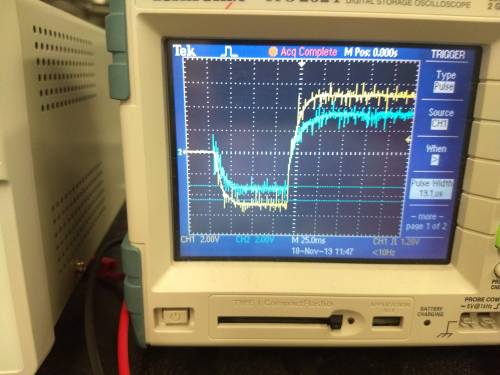
| 1234 | Move by +6 steps with command mv +6. Tower spikes to 685 mK. First few steps have flat coil waveforms, but had scope time too short to see full pulse train. |
| 1238 | Tower = 134 mK |
|---|---|
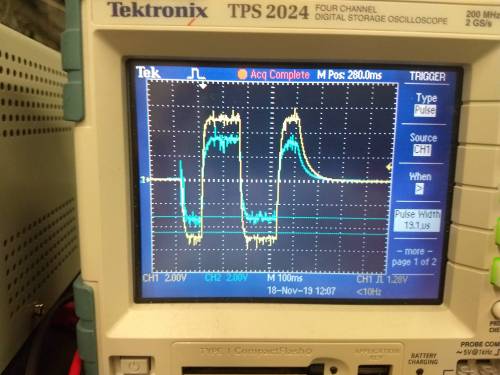
| 1244 | Tower = 62.5 mK Move by +6 steps with command mv +6. Tower spikes to 668 mK. Coil voltages are relatively flat, but beginnings of current reduction can be seen by last step. |
| 1255 | Tower = 59.6 mK Move by +6 steps with command mv +6. Tower spikes to 622 mK. |
|---|---|
| 1316 | Move by +6 steps using script /home/mast/cdms/arduino/stepper_loop.py set to 1 round of 6 steps. Tower spikes to 784 mK. |
| 1328 | Tower = 62.8 mK Move by 2x+6 steps with 10 min pause in between using script /home/mast/cdms/arduino/stepper_loop.py. Tower spikes to 675 mK. |
| 1338 | Tower spikes to 694 mK. Motor waveforms look as above, maybe a little earlier current loss. |
| 1352 | Tower = 52.9 mK Move by 5x+6 steps with 12 min pause in between using script /home/mast/cdms/arduino/stepper_loop.py. Tower spikes to 700 mK. |
| 1534 | Script seems to have worked. Tower spiked between 650 - 700 mK each time. Let's set the script to run over night like this to accumulate a decent distance. If we increment 75 times at this rate, it will take 15 hours and we'll move as much as 7.44 mm. |
| 1542 | Move by 75x+6 steps with 12 min pause in between using script /home/mast/cdms/arduino/stepper_loop.py. Send script output to /home/mast/cdms/arduino/stepper_loop.out. This way we can monitor the progress remotely. |
| 1607 | The 2nd move in this sequence heated a little more, to over 750 mK and the motor waveforms indicated early heating after the first ~2 steps. The 1st and 3rd moves only hit ~625 mK and the waveforms looked like there was little to no heating for all steps. So the tower spike temp may be an okay proxy for how successful each of these moves is. |
| 1625 | The 4th move is like the 2nd, hotter and with low current. All the moves are right on time. What's this about? The only difference from the last sequence of moves is the total number and that I'm piping the output to a file. |
| 1655 | The 5th, 6th, and 7th moves all seem to be closer to the cooler, higher current case. Looks like it's stabilizing now for whatever reason. |
| 1700 | Fill LN2 cold trap bath. |