2019/11/23 (Saturday)
| Setup | DIB1/2/4 → 3.2 MHz filters → cable 1/2/3 → gender changer 1/2/3 → movable source controller/board with external Feedback resistor/nothing → DCRC55(1)/DCRC33(2)/DCRC50(3) |
|---|---|
| Overnight | Ran a script that moved the source a few steps every few min, then did a hot Al flash. The last dataseries showed we were over the first blocker - this last move was about 0.5 mm, may or may not get us past the blocker (blocker is 2.6 mm wide). |
| 0800 | Tower/MC/Coldplate = 32.4/29.7/190 mK, Still = 1.54 K/ 0.120 mbar / 0 mW, G1/G2= 246/236 mbar, 1K Pot = 1.63 K / 20±1 mbar. MB = 35.5% |
| 0800 | Fill LN2 cold trap bath. |
| 0800 | Turn off motor power supply, power down arduino. Check that Keithley meter is not connected to breakout box. |
| 0800 | Check the channels - they all look good! Adjusted the driver offset on one of them to get the baseline near -0.9V |
| 0804 | Start 1x S1/S2=-4/+4,+4/-4 V loop of 30 min Bkg data series, Driver gain = 1, with 1000 initial randoms, with 30s flashes and 30 min cooldowns trigger on DCRC2pA/B/C = 8/8/8 ADC using sequence qbias_mp4_pm4_loop.msl |
| 0915 | Take a look at the first series this morning - it still looks like we are over the blocker. Let's move it another 32 steps. |
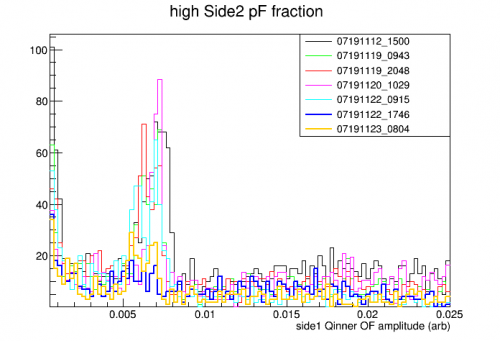
note that we don't have good Side2 charge info. By plotting the 60keV peak in Side1 qInner, we are effectively removing surface events, since the source is on Side2. So the above is the part of the 60keV peak that penetrates past the surface field.
| 1155 | Power arduino and connect to it via telnet. Arduino responds to two “marco”s with “polo”. Turn on motor power supply, which is set to 6.4 V. In telnet session set dwell to 40 ms. Scope is on. |
|---|---|
| 1150 | Check stepper_loop.py, “nrepeat” is still set to 8. |
| 1154 | Tower = 32.5 mK. Move 8x-4 steps with 4 min wait in between using stepper_loop.py. Pipe this output to /home/mast/cdms/arduino/stepper_loop.out. This is the second ~0.5mm step to see whether we get past the first blocker. This should end at 12:26. |
| 1212 | Start LHe transfer @ MB = 29.4% |
| 1225 | Move sequence is finished. Tower = 126 mK. Do a hot Al flash for 90s using the sequence Al_flash.msl. Tower peaks at 1.6 K. |
| 1235 | End LHe transfer @ MB = 79.3% |
| 1240 | Turn off motor power supply, power down arduino. Check that Keithley meter is not connected to breakout box. |
| 1250 | Tower = 60 mK and cooling. Check channels: all look good! |
| 1335 | Tower = 34.8 mK |
| 1345 | Tower = 34.4 mK |
| 1346 | Start 1x S1/S2=-4/+4,+4/-4 V loop of 30 min Bkg data series, Driver gain = 1, with 1000 initial randoms, with 30s flashes and 30 min cooldowns trigger on DCRC2pA/B/C = 8/8/8 ADC using sequence qbias_mp4_pm4_loop.msl |
| 1440 | Looked at 13:46 data series. We seem to still be over the blocker at least partially. Since we first found the blocker we've done two ~0.5 mm moves. The lowest 60keV rate was seen in the first blocker series - after the first move it rose a bit, and after the second it rose a bit more, but it's still only around 1/2 of the rate before we reached the blocker. so, let's do another 32-step move. |
| 1546 | Power arduino and connect to it via telnet. Arduino responds to two “marco”s with “polo”. Turn on motor power supply, which is set to 6.4 V. In telnet session set dwell to 40 ms. Scope is on. Telnet failed to connect the first time, had to restart the Arduino. |
| 1549 | Check stepper_loop.py, “nrepeat” is still set to 8. |
| 1555 | Tower = 33.3 mK. Move 8x-4 steps with 4 min wait in between using stepper_loop.py. Pipe this output to /home/mast/cdms/arduino/stepper_loop.out. This is the third ~0.5mm step to see whether we get past the first blocker. This should end at 4:27. |
| 1650 | Move sequence is finished. Tower = 41.2 mK. Do a hot Al flash for 90s using the sequence Al_flash.msl. Tower peaks at 1.6 K. |
| 1650 | Turn off motor power supply, power down arduino. |
| 1735 | Tower = 39.3 mK and cooling. Check all phonon channels - they all look OK. |
| 1758 | Tower = 35.1 mK |
| 1759 | Start 1x S1/S2=-4/+4,+4/-4 V loop of 30 min Bkg data series, Driver gain = 1, with 1000 initial randoms, with 30s flashes and 30 min cooldowns trigger on DCRC2pA/B/C = 8/8/8 ADC using sequence qbias_mp4_pm4_loop.msl |
| 1950 | OK, this series seems to be past the blocker, right on schedule. |
| 2010 | Power arduino and connect to it via telnet. Arduino responds to two “marco”s with “polo”. Turn on motor power supply, which is set to 6.4 V. In telnet session set dwell to 40 ms. Scope is on. |
| 2010 | Edit stepper_loop.py, change “nrepeat” from 8 to 255. |
| 2013 | Move 255x-4 steps with 4 min wait in between using stepper_loop.py. Pipe this output to /home/mast/cdms/arduino/stepper_loop.out. This should push us out to y=-24.3 mm. It will and at 13:13 tomorrow. |
jake: (507) 213-4607